Robotics · AI · Autonomous Navigation
Earth Rovers
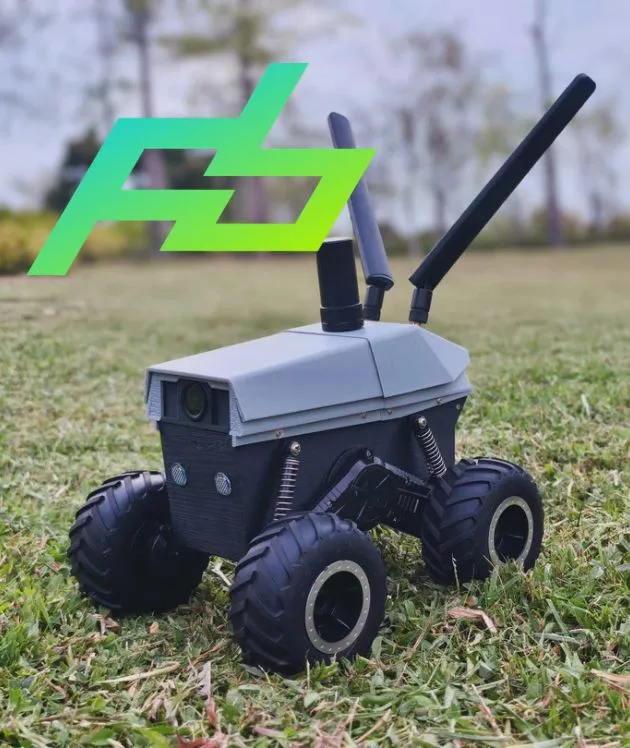
Sidewalk robots are a hard robotics problem disguised as an easy one. The terrain changes every few metres, the obstacles have opinions, and the network you depend on is whatever the street happens to give you. Earth Rovers is a fleet built to work in exactly that.
Results
- 01Deployed across 14 global sites
- 029,000+ hours of teleoperation released as open datasets on Hugging Face
- 03ROS-based autonomous navigation with onboard perception and custom SLAM
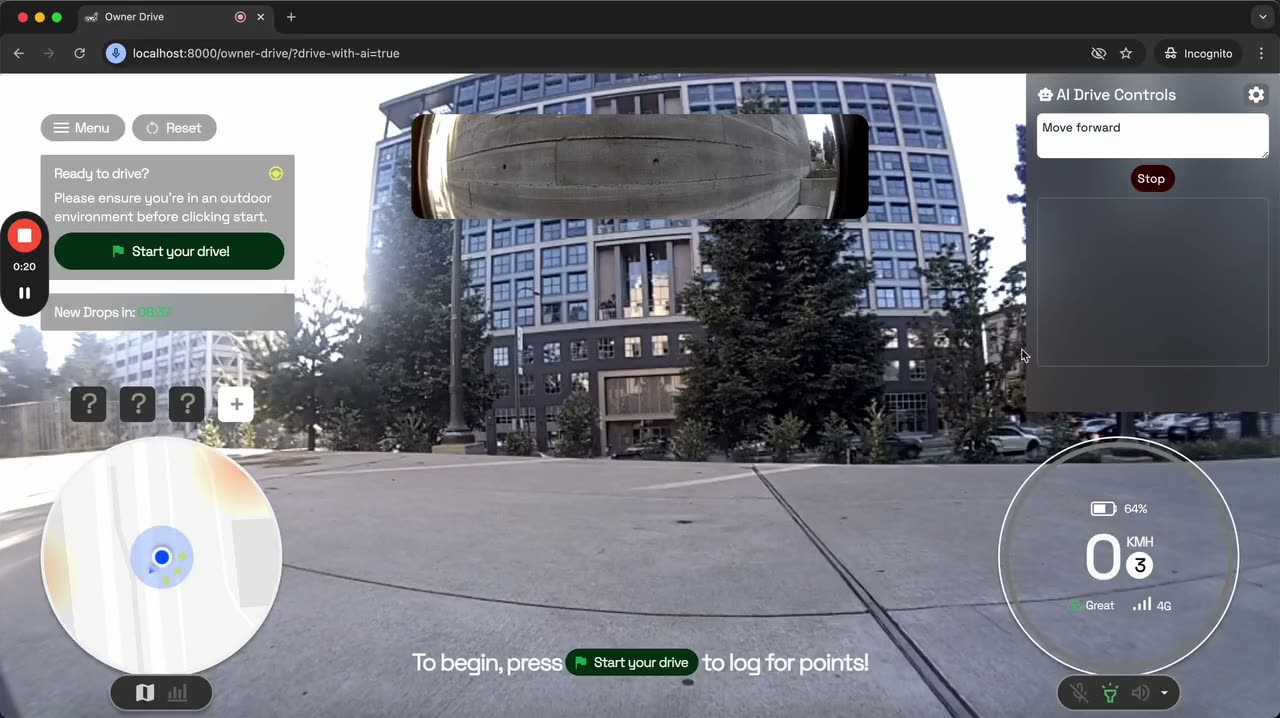
- 04Live teleoperation interface for human-in-the-loop missions
- 05Underpinned the Earth Rover Challenge at IROS, documented in IEEE Robotics & Automation Magazine
01
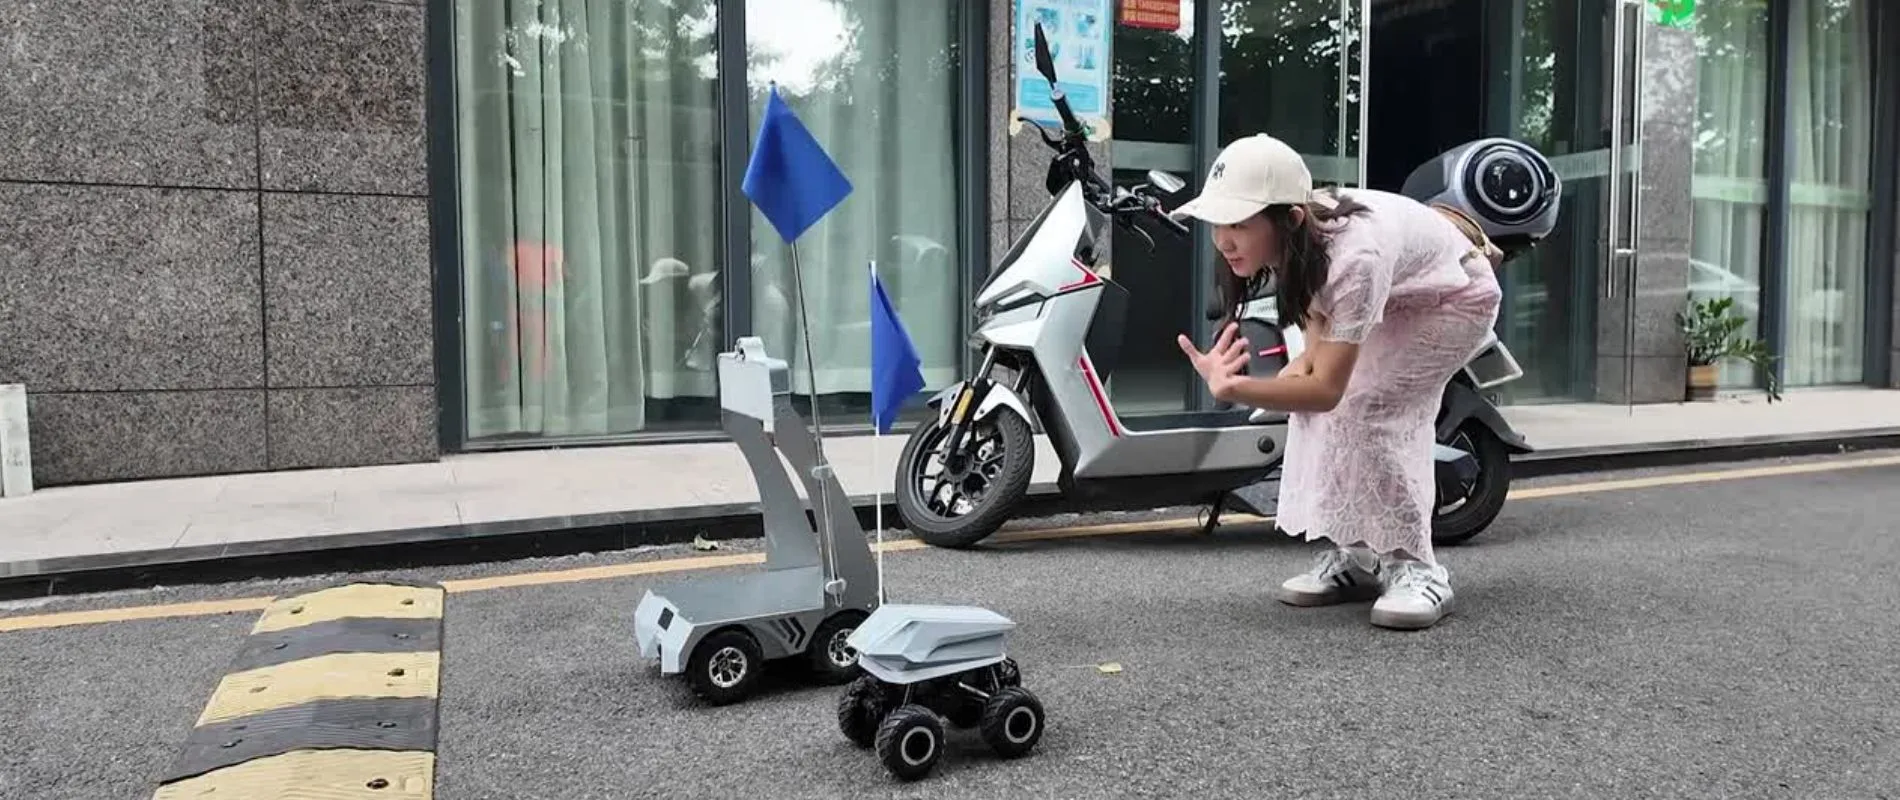
Perception on the street
GPS drops between buildings and the terrain changes every few metres. Custom SLAM handles localisation, vision handles detection, and the planner replans continuously instead of following a route.
02
When autonomy gives up
Full autonomy is not the goal on every mission. Operators take over when the stack meets something new, then hand it back. Every intervention is a labelled example of exactly where autonomy failed.
03
9,000 hours, made public
The teleoperation data did not stay private. FrodoBots-2K and Berkeley-FrodoBots-7K sit on Hugging Face, used by research groups that will never touch the hardware.
04
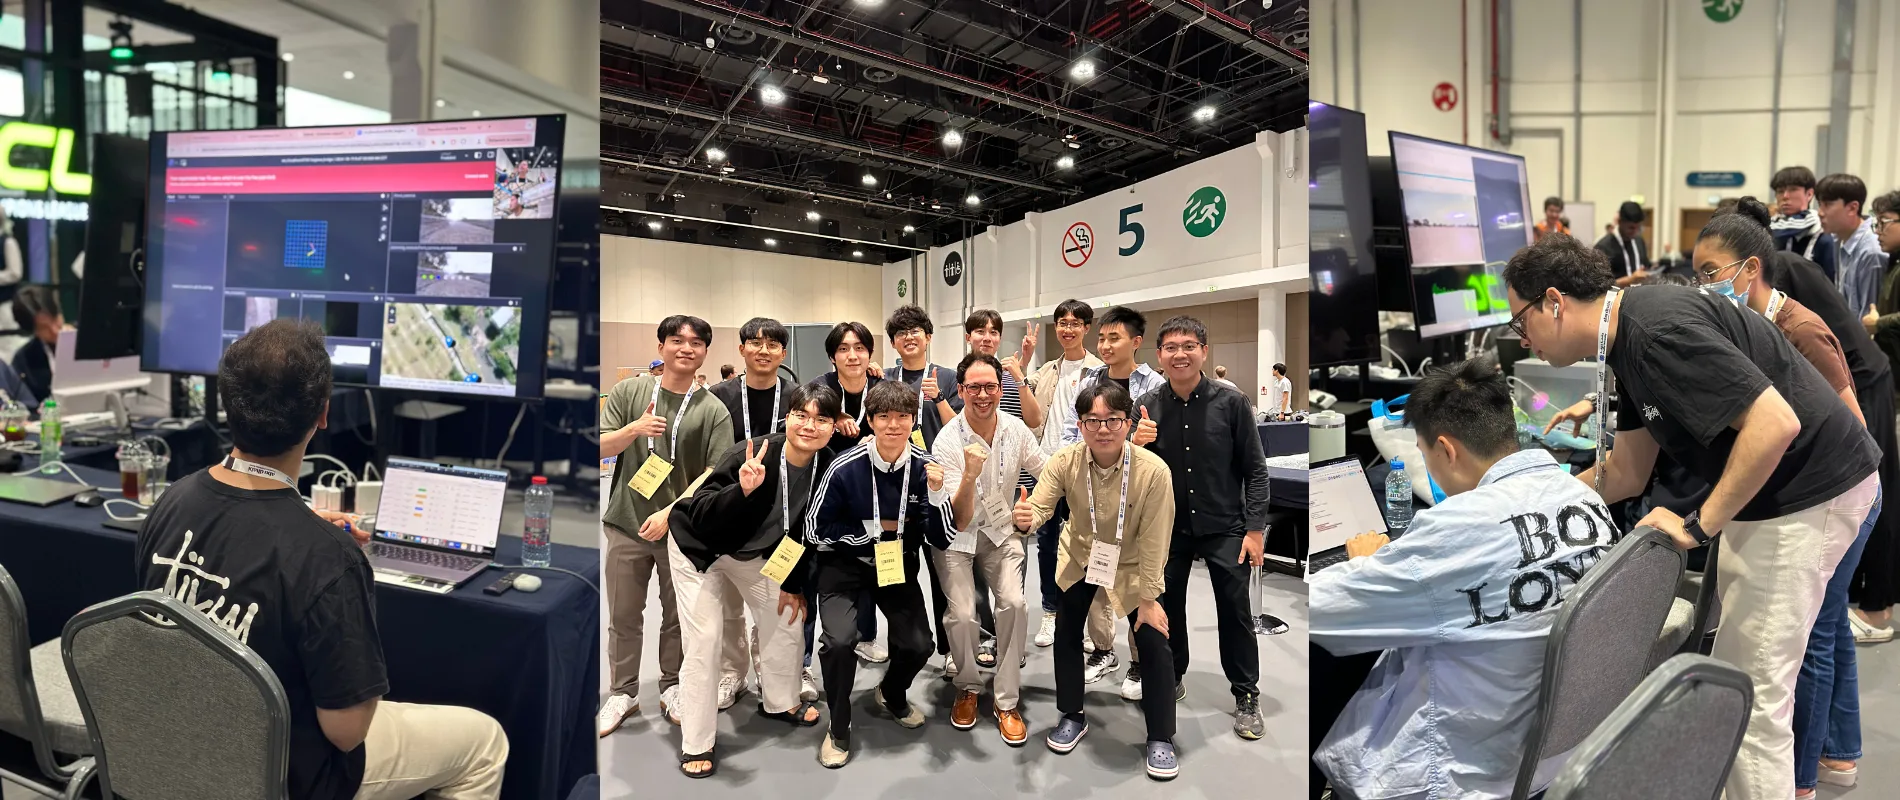
From fleet to benchmark
The same platform became the Earth Rover Challenge at IROS: teams submit navigation policies and are scored on real robots in real cities instead of in simulation.